Sol-0
A simulated rover that teaches itself to drive on a procedural planet, with very small neural networks: you watch it live.
In short
- Four small neural networks written with numpy only: the pilot, the predictor, the visual encoder and the energy manager.
- Everything shown comes from the real computation; the journal is not written by a language model; any sol can be replayed identically.
- The rover lives continuously on a server, one sol every 15 minutes; a GitHub Action replays a recent sol on the GitHub profile.
- Snapshot of 19 November 2026: the live page showed sol 612, stage 2 (“learning to drive”).
- I pay for the server and the domain name; the live page opens in a tab, it refuses to be embedded in another page.
- All rights reserved.
- Stack
- Python 3.12, numpy, GitHub Actions; live page in HTML, CSS and JavaScript
- Role
- Personal project: sole author of the working copy’s history (325 commits).
- AI
- developed with AI agents (Claude)
- Proves
- C3 Administrer (administer) validatedA service kept running continuously: a server for the live page, scheduled GitHub Actions, a page with a strict security policy.
- C5 Conduire (lead) validatedA project run in stages, with a brief, milestones and audits.
- Demo
- sol0.fr
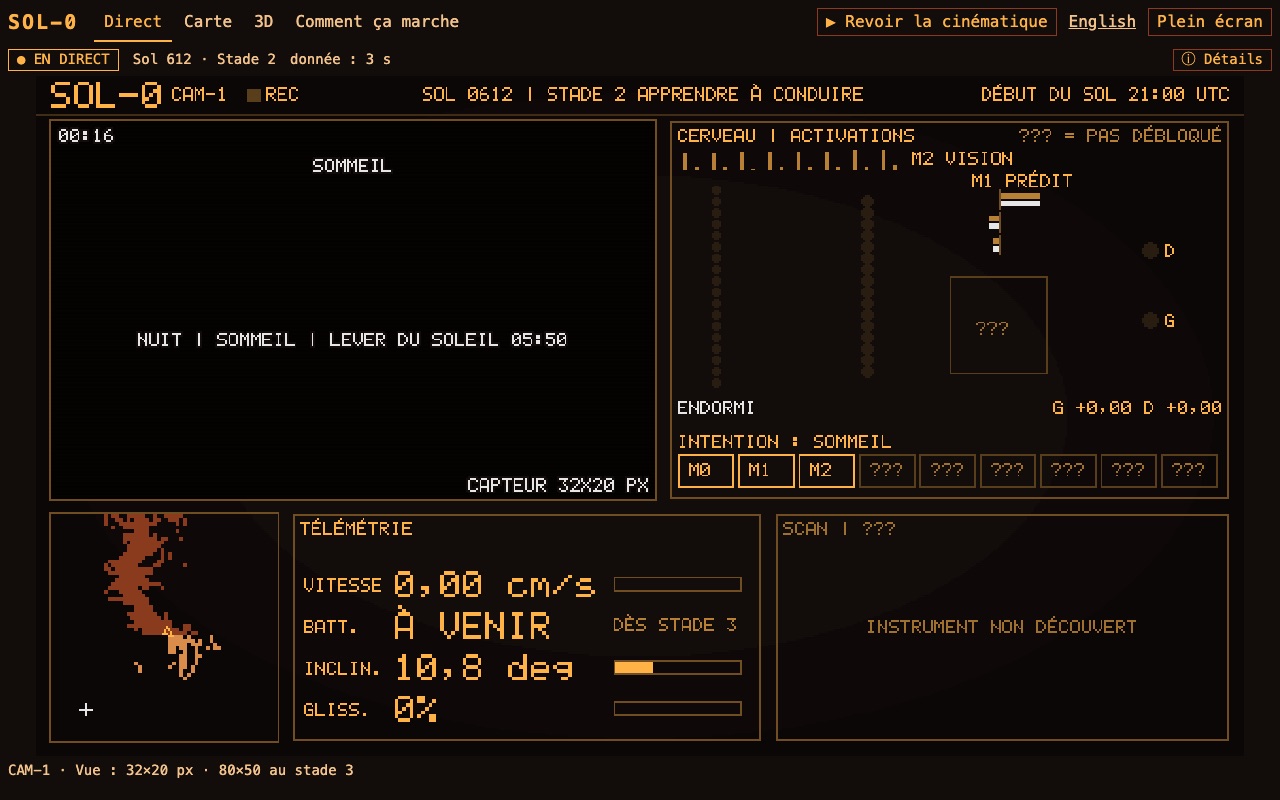
Animation: a ground line of unlit dots; a small rover, a box, a mast with an orange lamp and two turning wheels, crosses it from left to right and leaves behind a track of dots that fade out little by little.